Yiqin Li

PhD Student · University College London

I am a PhD student at University College London (UCL), supervised by Zhibin Li. I received my MEng in Computing (AI & Machine Learning) from Imperial College London with First-class Honours.

My research interests lie in combining multimodal foundation models with low-latency visuomotor policies to build robust robot systems that operate reliably in the real world. I am also interested in world models and foundation models grounded in physical interaction, particularly how prediction and action can be learned together.

Yiqin Li

research interests

How can robots connect broad multimodal knowledge with responsive control, and learn predictive models through physical interaction?

Foundation Models & Real-Time Control

Combining multimodal foundation models with low-latency visuomotor policies, with an emphasis on responsive closed-loop behaviour and reliable deployment on real robots.

World Models & Physical Interaction

Exploring how world models and foundation models can learn from physical interaction, and how predictive representations can support robot learning, planning, and control.


selected research & projects

Ongoing · UCL PhD

TacDexter: Visuo-Tactile Dexterous Manipulation Dataset

Tactile Sensing · Dexterous Teleoperation · Open Dataset

A teleoperation and data-collection system for a 12-DoF tactile dexterous hand (XHAND1), combining hand tracking, VR wrist pose, egocentric RGB, and fingertip tactile sensing. The goal is an open visuo-tactile dataset for learning contact-rich dexterous manipulation.

Ongoing · UCL PhD

RRD-VLA: Rectified Recurrent-Depth VLA

VLA Efficiency · Distillation · Low-Latency Control

Recurrent-depth VLAs improve as their action head iterates more, but every iteration adds latency to a real-time control loop. We rectify the recurrent core by distillation so that one or two iterations reach what the full loop converges to, evaluated closed-loop on CALVIN, LIBERO, and SimplerEnv.

Dexterous-Hand VLA Pipeline

Real Robot Pipeline · Teleoperation · 22-DoF Arm-Hand Coordination

At Shanghai Jiao Tong University, I built the teleoperation, data collection, and evaluation stack for a LinkerHand O6 + xArm6 platform. This work grounds the real-robot side of my current interests, especially contact-rich data collection, dexterous action spaces, and deployment-time evaluation.

Language-Guided Imitation Learning

MEng Thesis · Language-Conditioned Manipulation · Closed-Loop Recovery

My MEng thesis built a closed-loop system where an LLM planner decomposes natural-language commands into a sub-task DAG and a behaviour-tree controller orchestrates perception, policy execution, and automatic recovery. The project achieved 100% success on pick-and-place and a 2.4× improvement over a code-as-policy baseline.

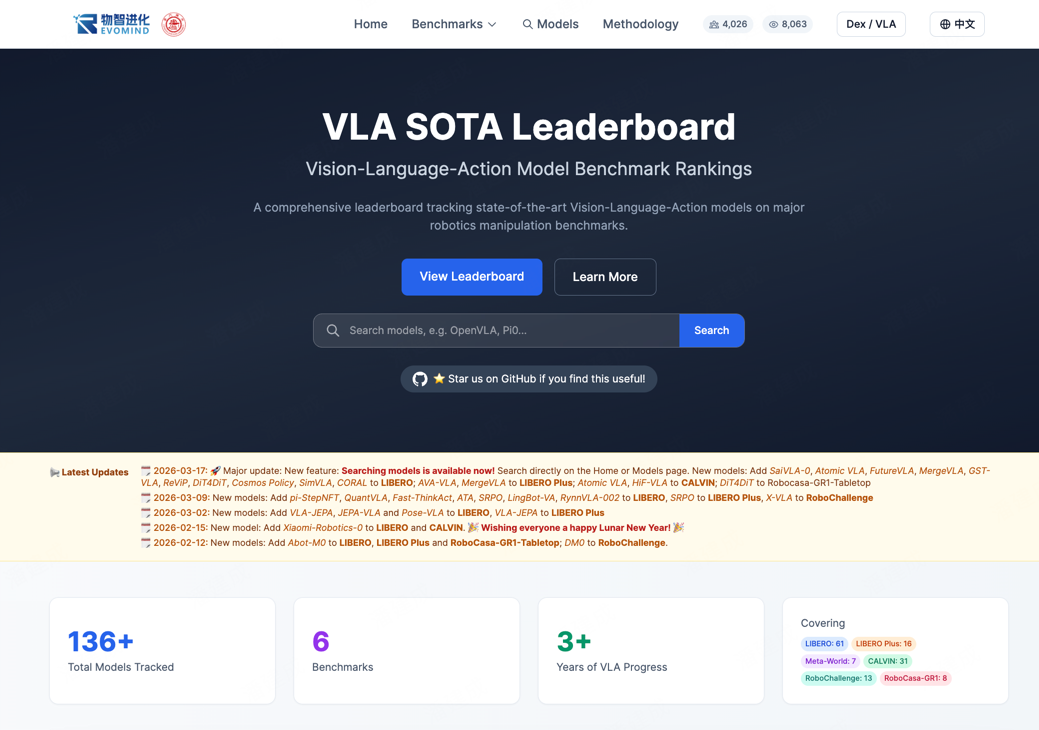
Evo-SOTA VLA Benchmark Leaderboard

Evo-SOTA — VLA Benchmark Leaderboard

Benchmarking Infrastructure · VLA Landscape Analysis · Open Source

I built and maintain an open-source leaderboard comparing Vision-Language-Action models across eight benchmarks, including LIBERO, CALVIN, Meta-World, RoboChallenge, and RoboTwin 2.0, alongside a dexterous-manipulation track. This project helps me systematically compare architectures, training data sources, and post-training strategies across the current VLA landscape.


background

10/2026 — Present

PhD Student · University College London

Supervised by Zhibin Li. Research interests in multimodal foundation models, low-latency visuomotor policies, world models, and learning through physical interaction.

04/2026 — 10/2026

Research Assistant · University College London

Research on foundation models and real-world robot learning. Completed the RAI project during this period, developing robot control, data collection, policy training, and evaluation infrastructure.

12/2025 — 04/2026

Research Assistant · Shanghai Jiao Tong University

Research with Professor Bo Zhao on Vision-Language-Action models for dexterous manipulation and VLA benchmarking (Evo-SOTA). Built teleoperation, data collection, training, and evaluation pipelines for a LinkerHand O6 + xArm6 platform.

06/2025 — 12/2025

Applied Scientist Intern · Thomson Reuters Labs

Developed agentic capabilities for Westlaw Deep Research Agent and owned guardrails for query-intent classification and policy routing. Benchmarked and fine-tuned small language models for guardrail classification.

2021 — 2025

MEng Computing (AI & ML) · Imperial College London

First-class Honours. Thesis on multimodal imitation learning for tabletop manipulation. Coursework in deep learning, computer vision, reinforcement learning, NLP, and robotics.

2024

NLP Researcher Intern · Huawei

Built LLM-based pipelines for automated knowledge-graph construction on large-scale GPU clusters. Acknowledged in a Findings of ACL 2025 paper.


beyond the lab

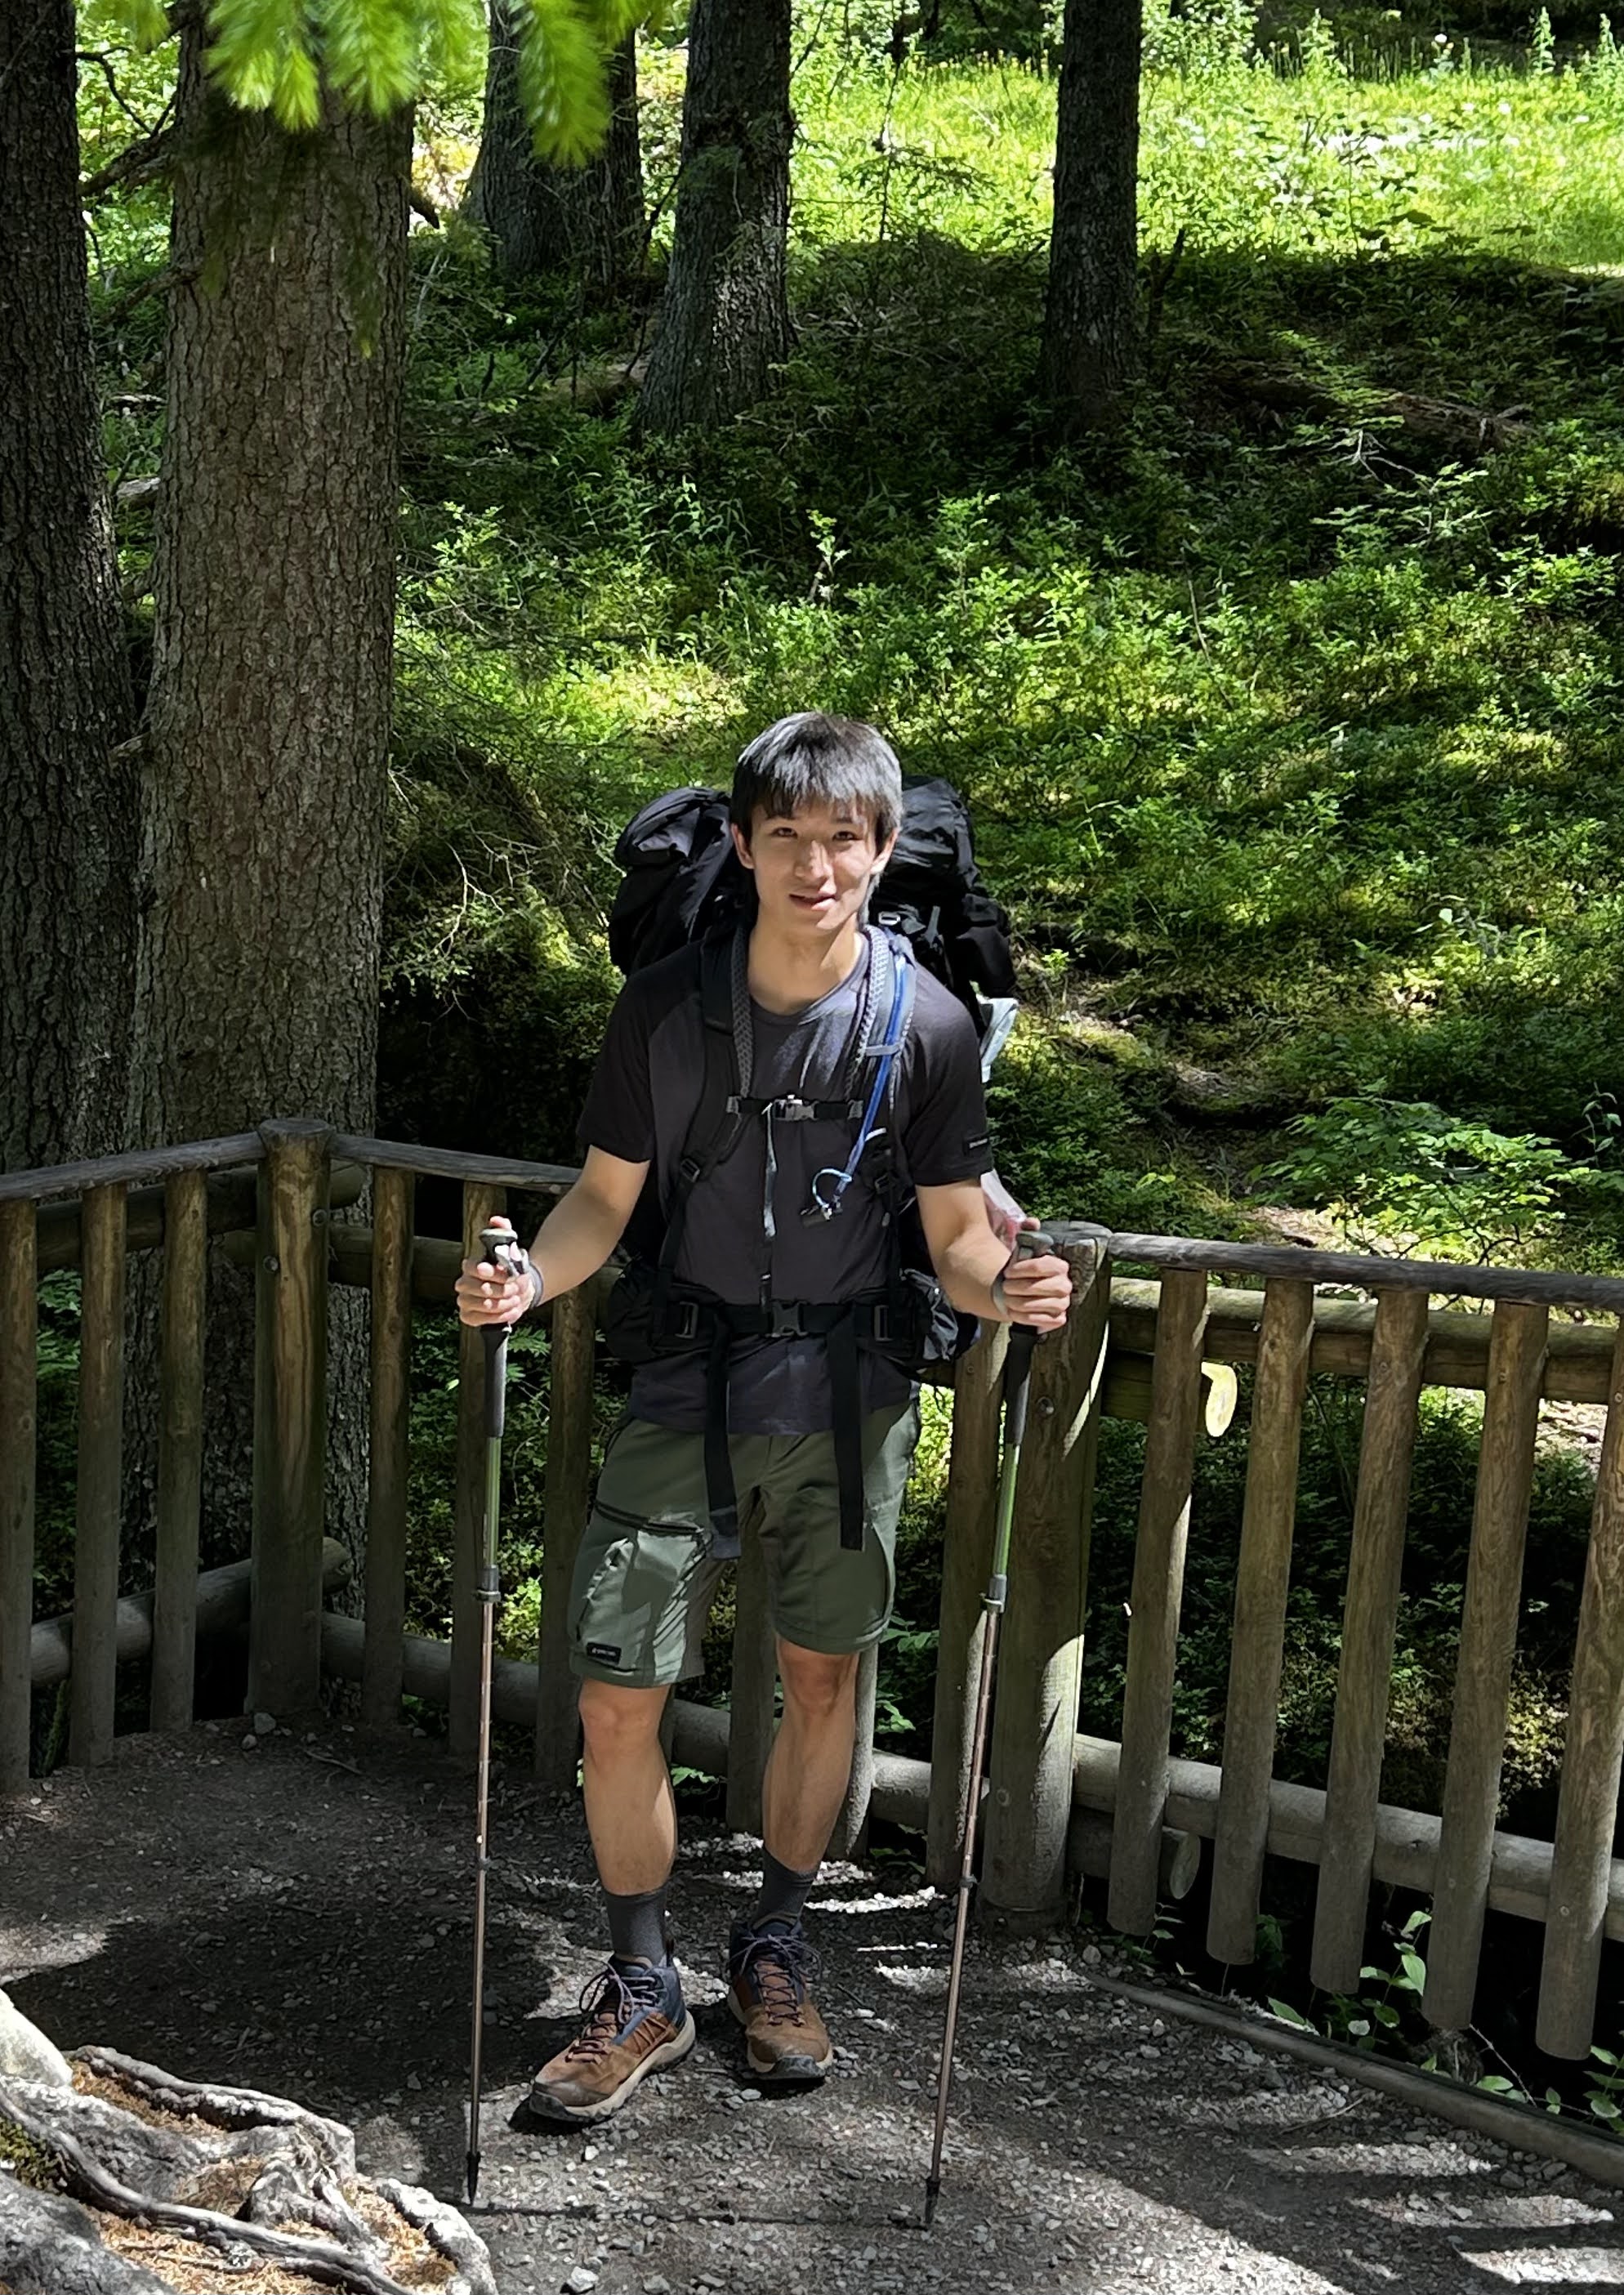
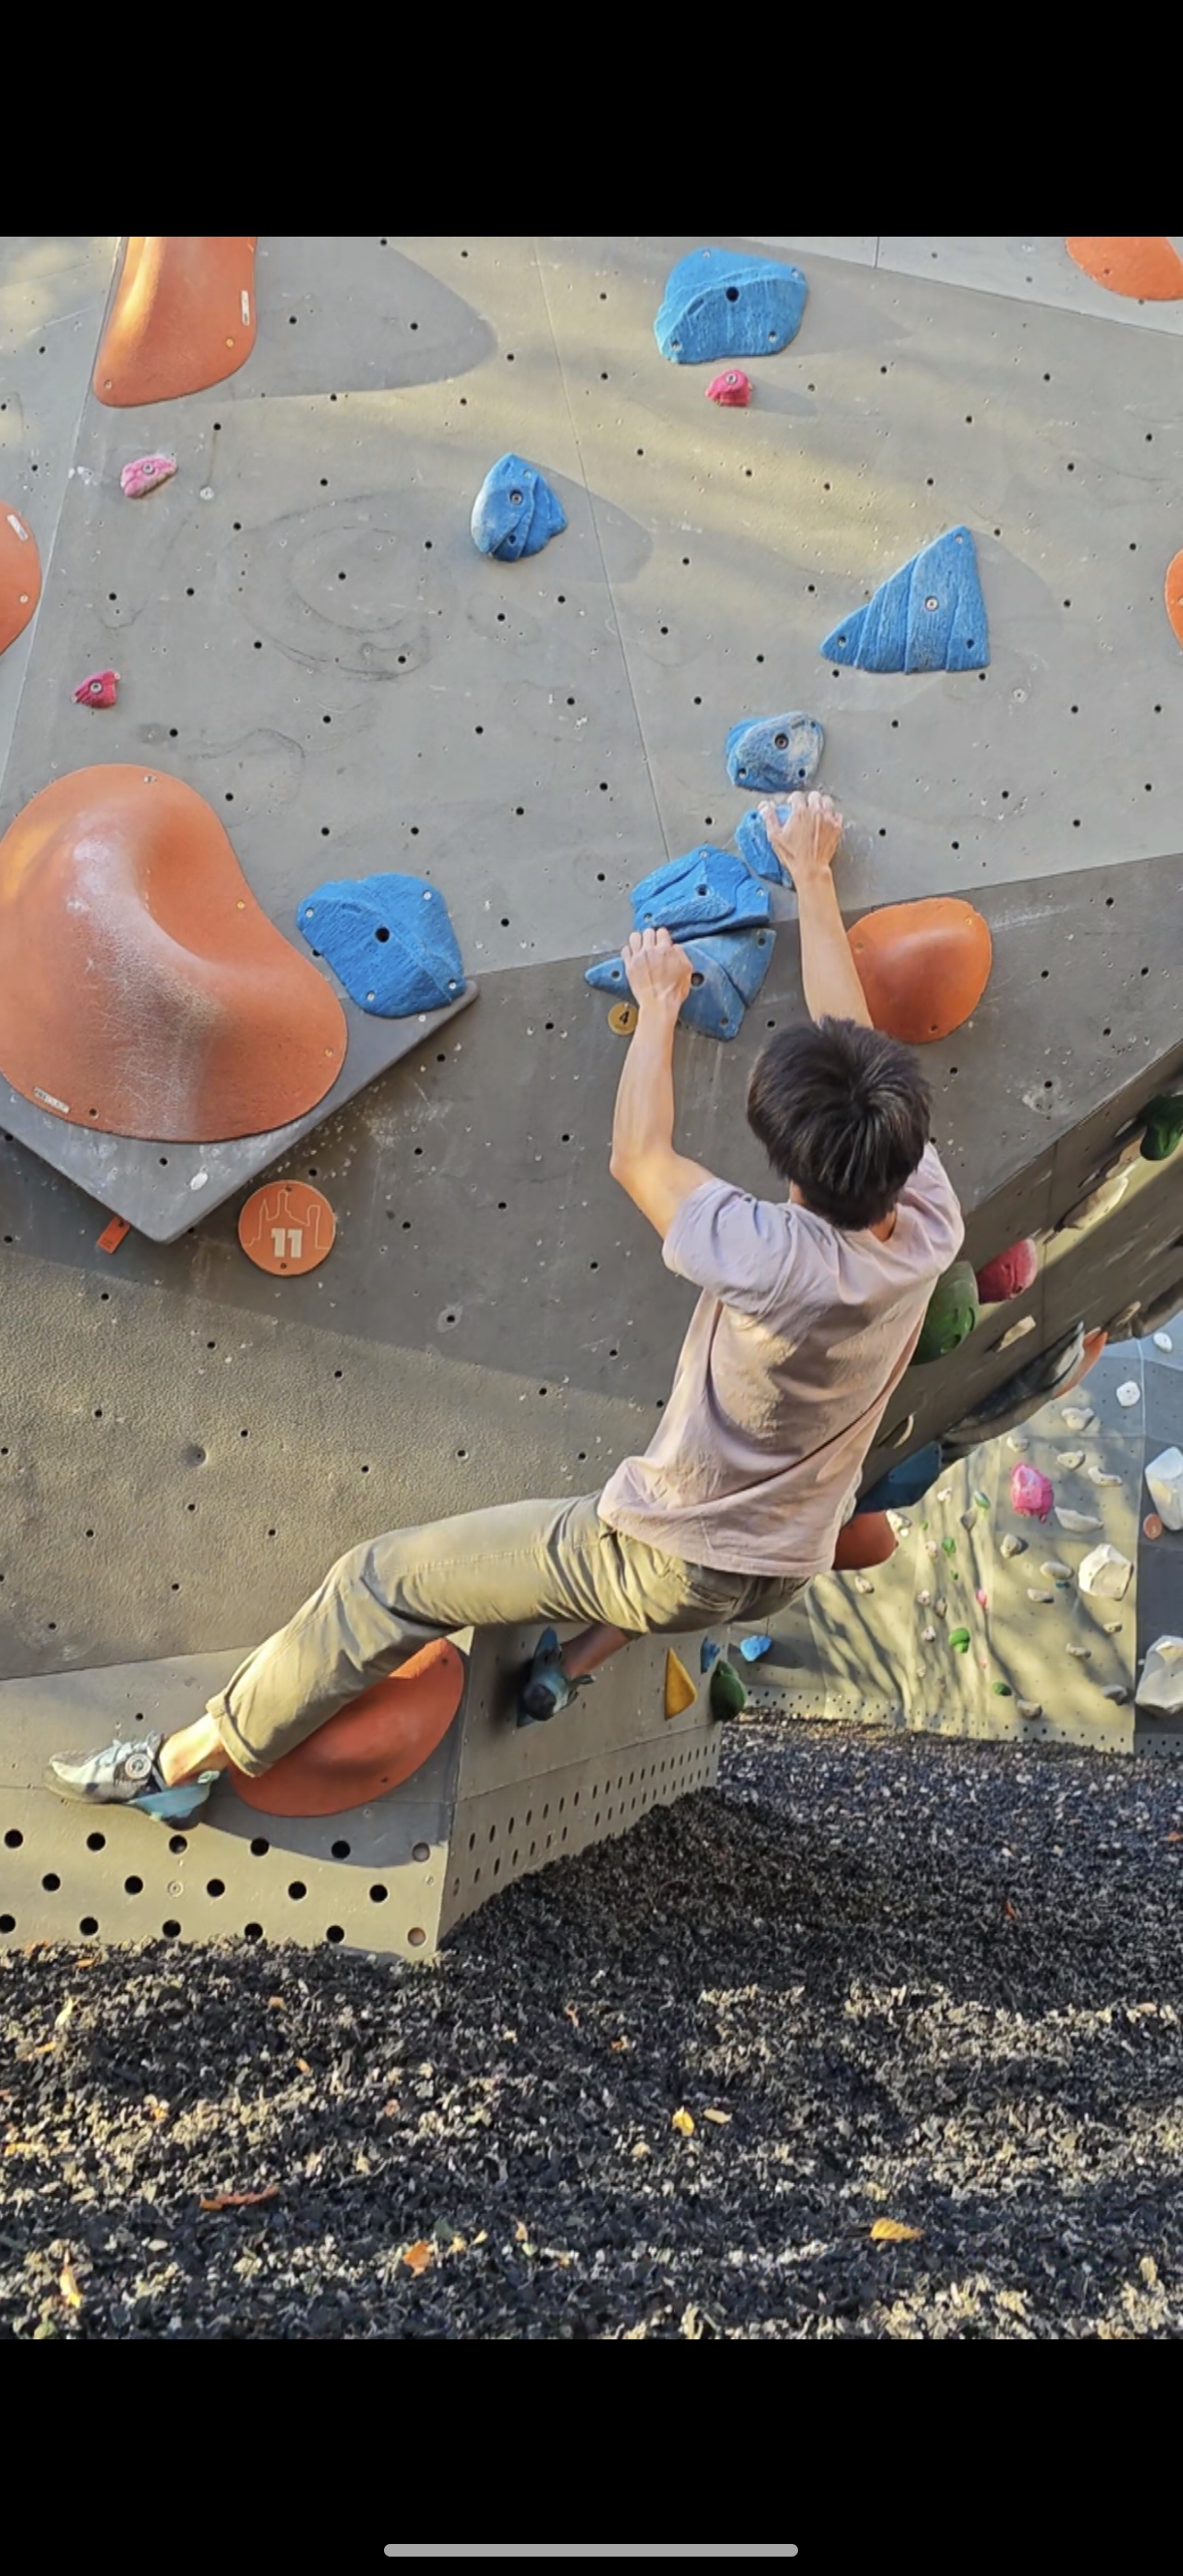
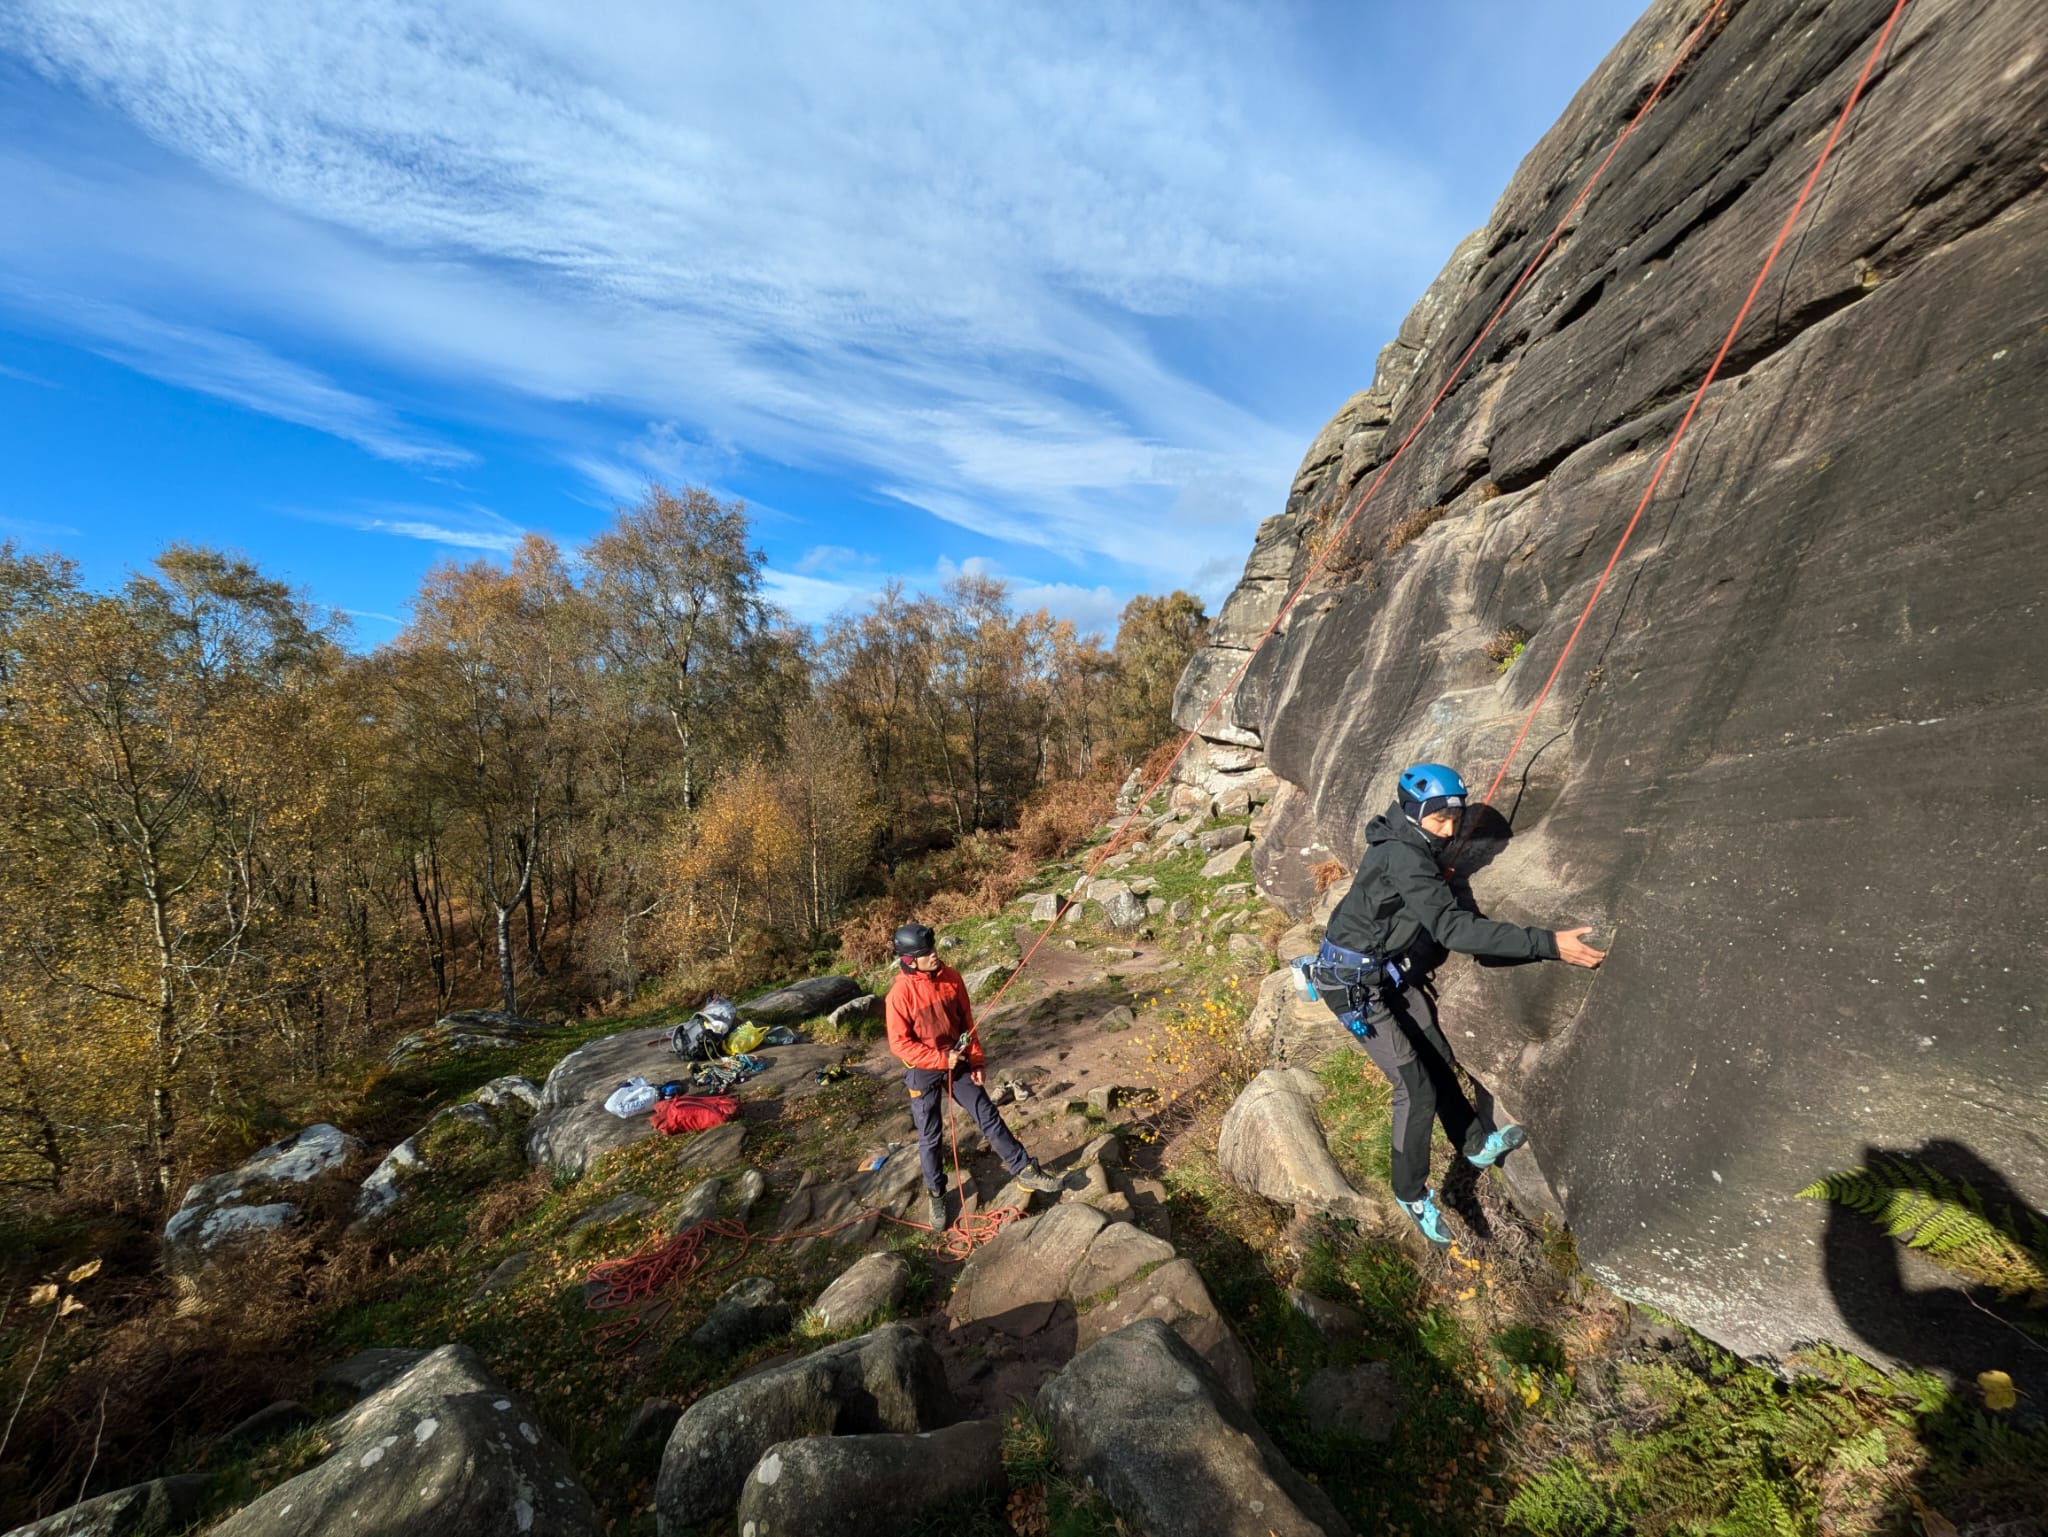
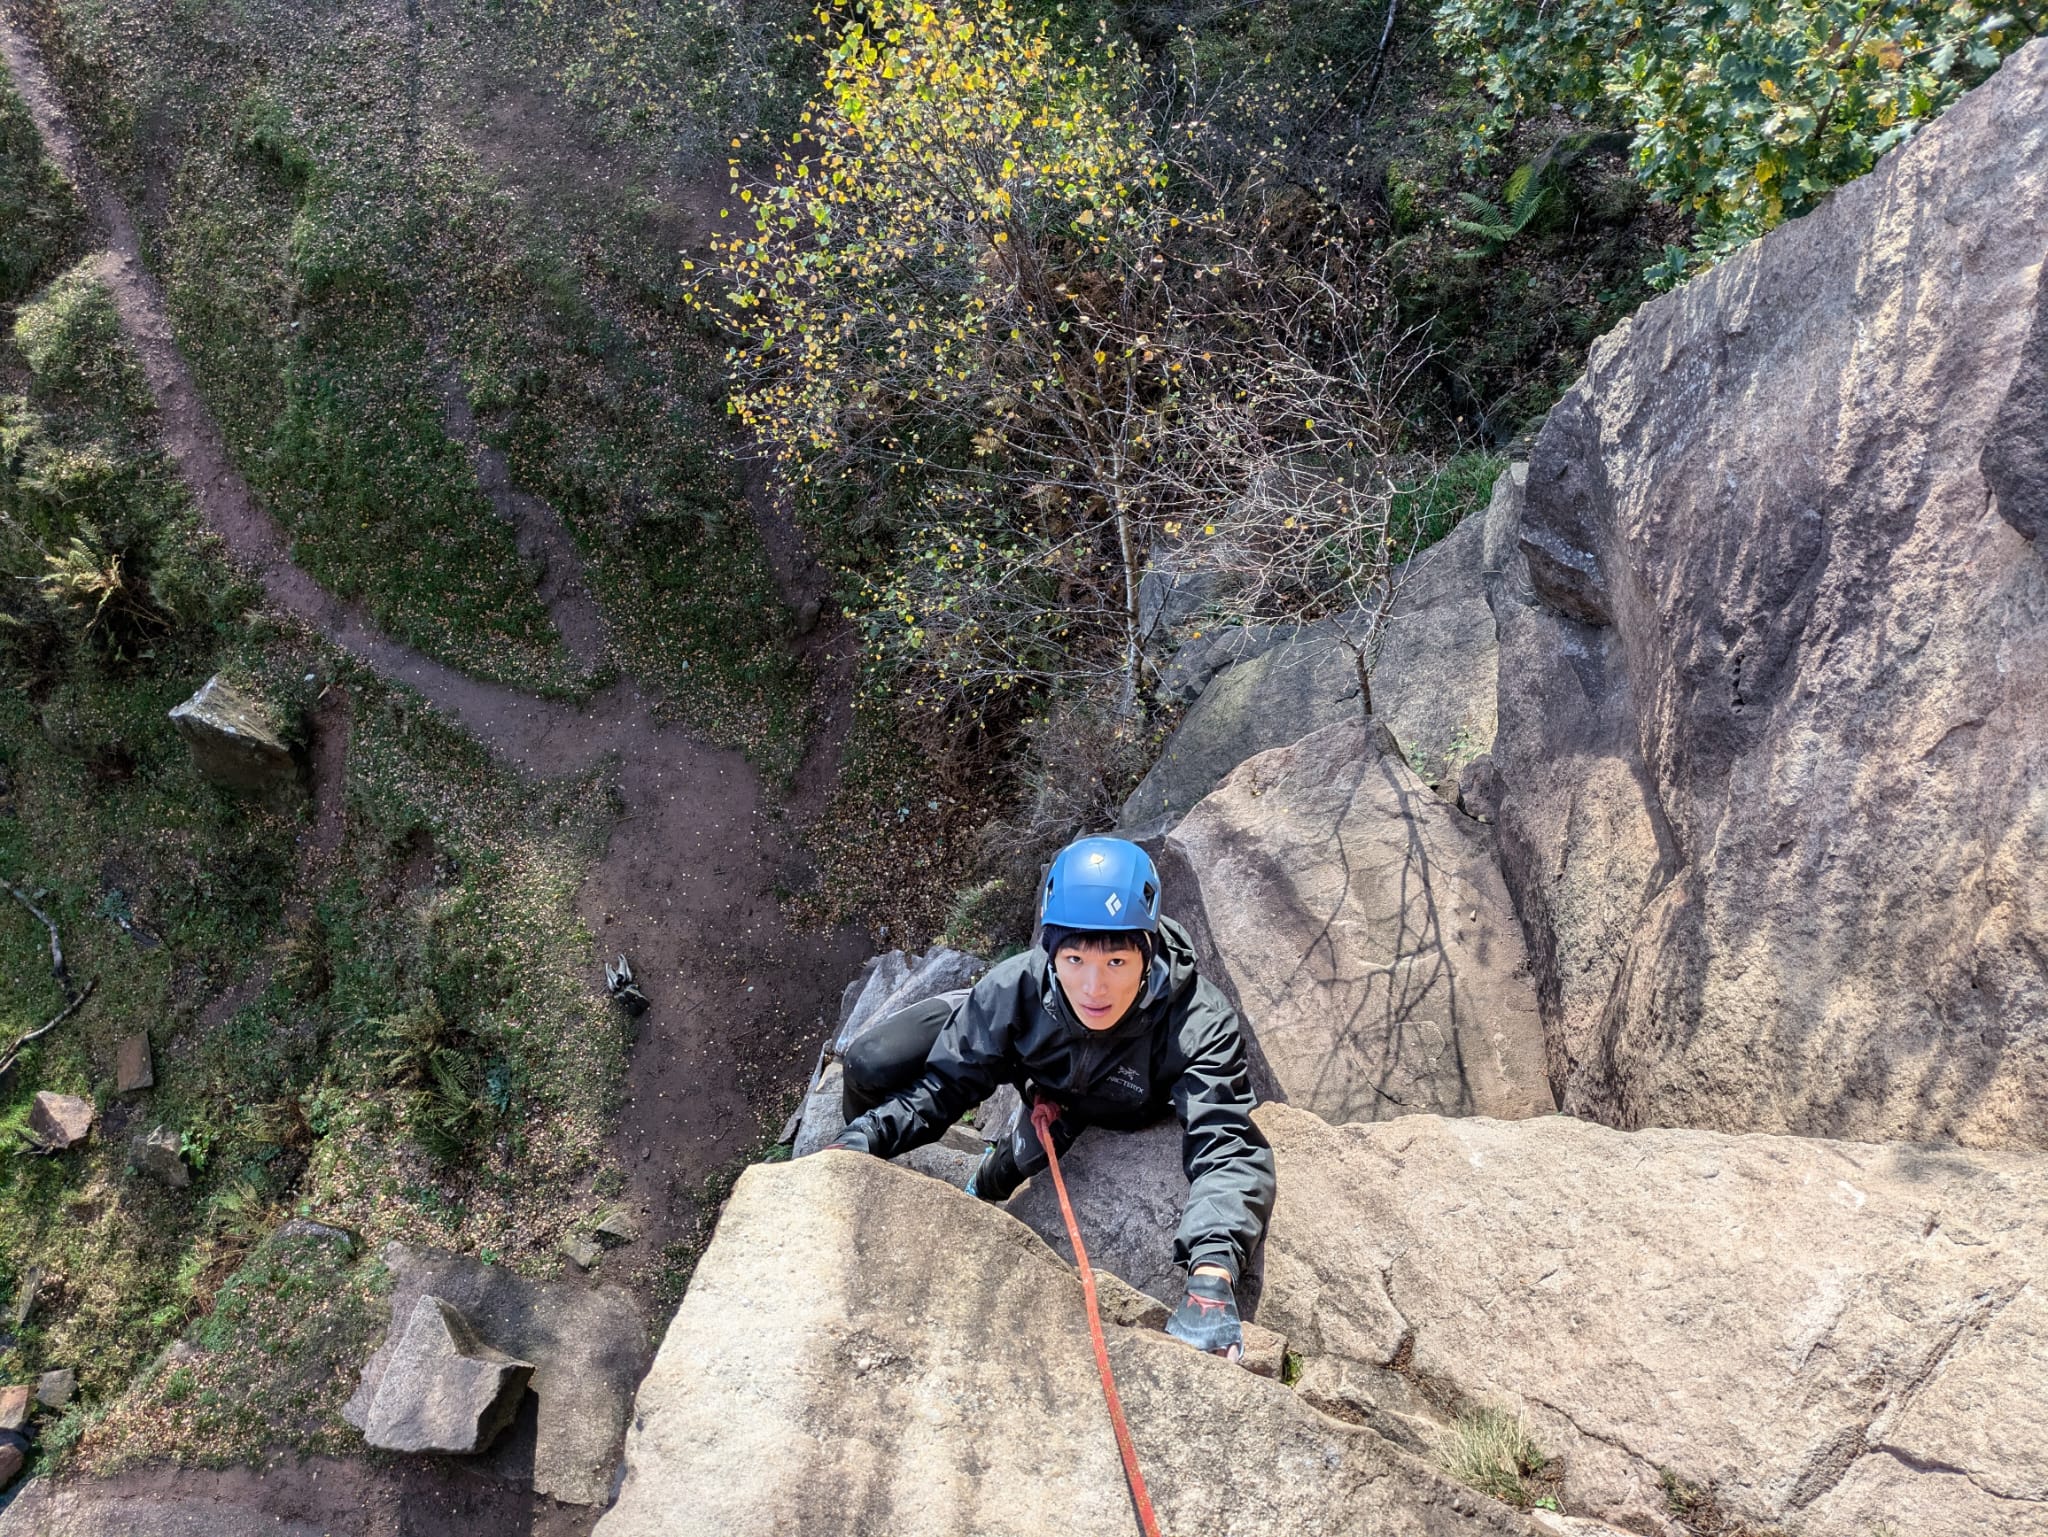
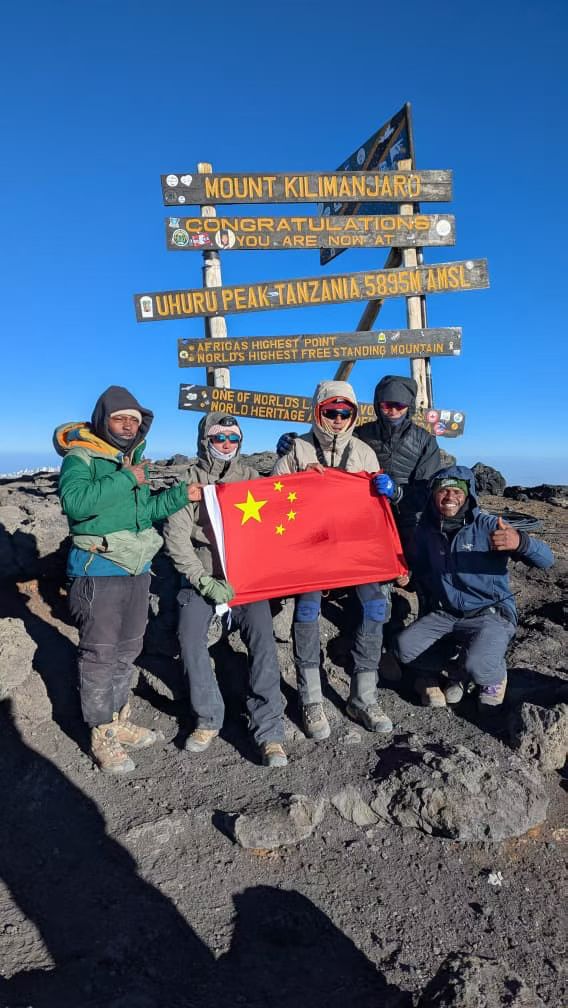
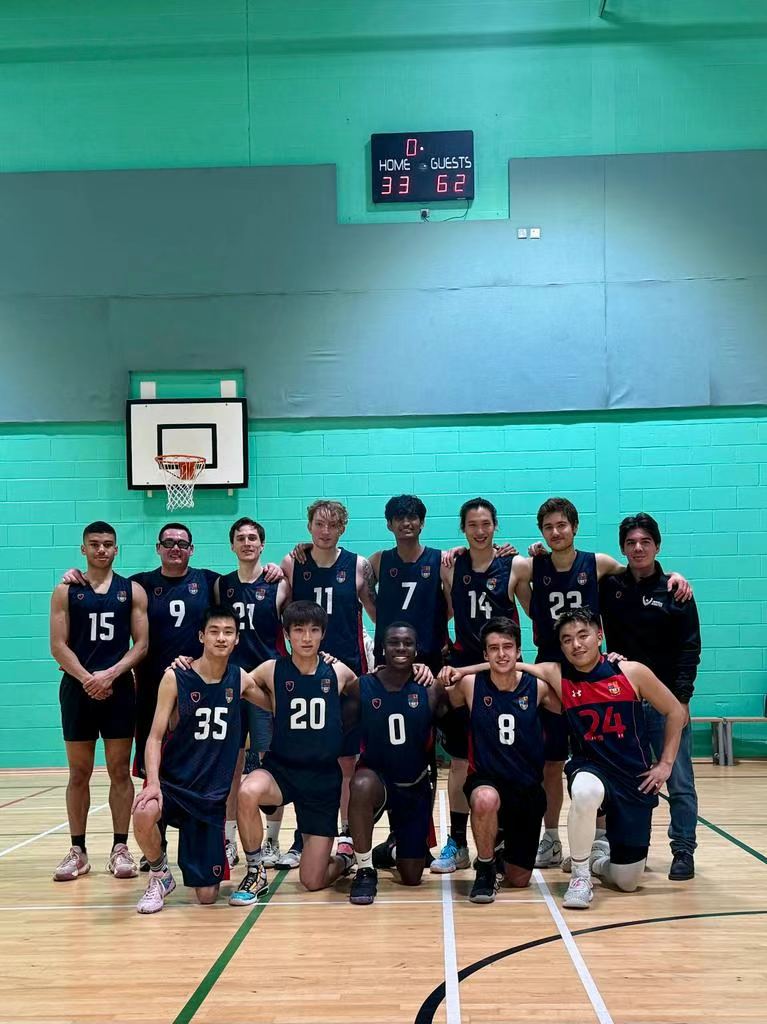
Outside research, I spend most of my time climbing. I summited Kilimanjaro and played on Imperial College's Men's 1st Basketball team.

Bouldering
Rock climbing outdoors
Rock climbing
Kilimanjaro summit
Imperial Basketball team